Projects

Research and engineering projects spanning system identification, feedback control, biosignal sensing, embedded implementation and soft robotics.

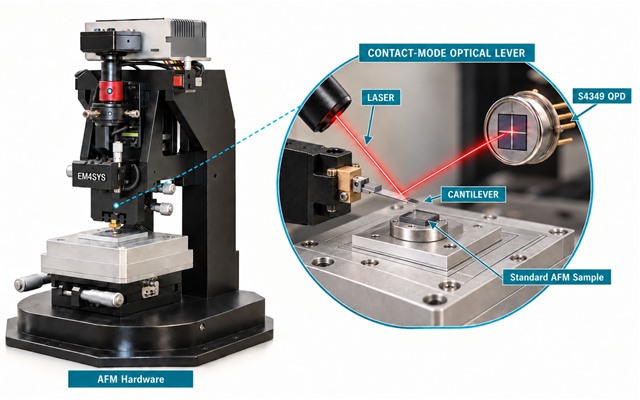
Concept illustrationThe complete AFM, optical-lever readout and embedded Z-axis feedback path. Trace–retrace scans →

Current research GIST · September 2025 – present

Model-Based Digital PI Control for High-Speed Contact-Mode AFM

Frequency-response identification, embedded implementation and trace–retrace evaluation of the Z-axis feedback loop.

ChallengeMaintain Z-axis tracking in contact-mode AFM as the scan frequency increases.

ContributionSystem identification, controller design, STM32 implementation, analog front-end revision and imaging experiments within the laboratory project.

EvidenceTrace–retrace r ≥ 0.977 through 5 Hz; agreement degrades at higher scan rates.
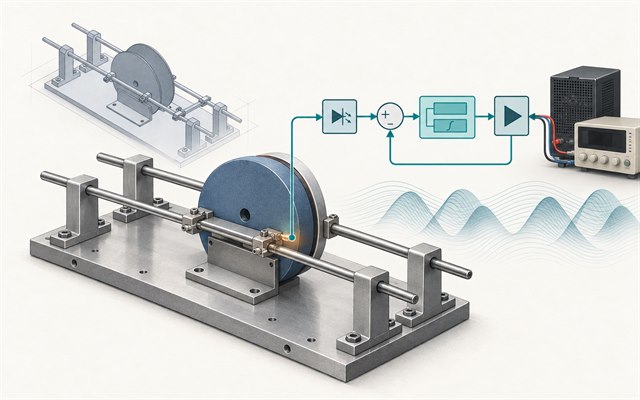
Concept illustrationThe built stage, current drive and analog feedback loop.

Research project GIST · Winter 2025–26

Voice-Coil Actuator Positioning System

Identification and analog feedback control of a stage with no restoring spring.

ChallengeControl a single-axis voice-coil stage whose plant has no restoring spring.

ContributionMechanical bench, current drive, identification and six analog compensators — an individual project throughout.

EvidenceSix compensators built and tested; lead compensation retained following bench evaluation.

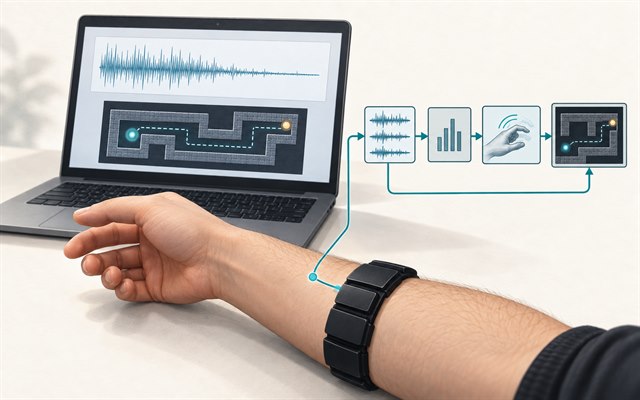
Concept illustrationMuscle activity becomes a real-time interactive command.

Research project NUST · June 2022 – August 2023

Real-Time sEMG Rehabilitation Interface

Eight-channel hand-state estimation for post-stroke upper-limb training.

ChallengeEstimate intended hand states online from eight channels of forearm sEMG.

ContributionAcquisition and feature pipeline, classifier comparison, deployment, three task interfaces and the evaluation protocol.

Evidence150 ms classification window, online 1–3 DOF interfaces, and the MUSED-I dataset. No clinical outcome was assessed.

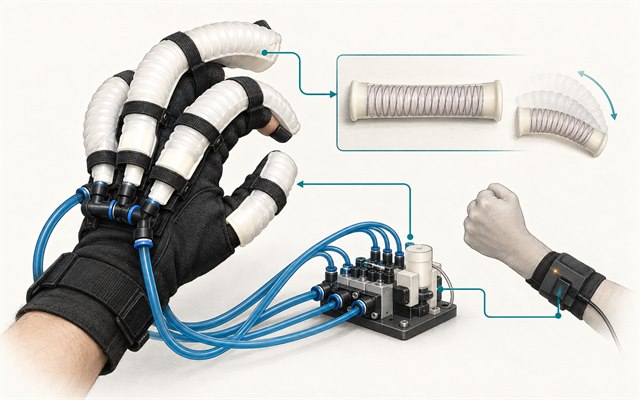
Concept illustrationThe wearable prototype, pneumatic drive and intended control link.

Team project · Final year NUST · 2022 – 2023

REHABOTICS Pneumatic Soft Robotic Glove

Fibre-reinforced silicone bending actuators for hand rehabilitation.

ChallengeDevelop fibre-reinforced pneumatic actuators for a wearable rehabilitation glove.

ContributionThree actuator geometries, ANSYS analysis, fabrication and the pneumatic drive, in a team of four.

EvidenceBench-measured 120–180° actuator-segment flexion at 100 kPa. Functional hand performance was not assessed.